Description
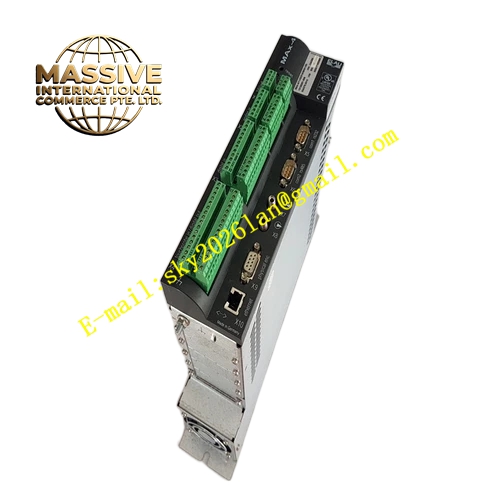
ELAU MAX‑4‑11‑03‑016‑08‑1‑1‑00
Technical Specifications CPU Core: Real‑time optimized industrial processor Program Memory: 16 MB Flash Data Working Memory: 8 MB RAM Maximum Controlled Axis Count: 8 axes Communication Interfaces: SERCOS fiber‑optic interface, Ethernet service port, RS232 serial port, RS485 interface On‑board Digital Inputs: 12 points On‑board Digital Outputs: 8 points Power Supply: DC24V, 1.5 A rated consumption Protection Class: IP20 Operating Ambient Temperature: 0℃ to +55℃ Storage Temperature: ‑25℃ to +70℃ Mounting Type: Standard DIN‑rail cabinet mounting
Functional Features Unifies IEC‑61131‑3 standard sequential logic control and hard‑real‑time motion computation inside single hardware unit. Supports electronic cam profiling, dynamic electronic gear ratio adjustment, flying‑shear cutting and mark registration multi‑axis synchronization functions. SERCOS fiber‑optic bus delivers high electromagnetic interference immunity and microsecond‑level inter‑axis synchronization accuracy. Non‑volatile flash memory retains user application program, production recipe dataset and configuration parameters after power‑off event. Comprehensive built‑in diagnostic system records bus communication faults, servo axis error codes and digital I/O historical status data. Ethernet interface supports program downloading, online debugging and real‑time equipment status monitoring. RS232 and RS485 serial ports realize data exchange with peripheral auxiliary devices. Hardware watchdog circuit guarantees stable operation under abnormal operating conditions.
Application Scenarios Medium‑size multi‑axis packaging machines; label processing automated lines; secondary packaging handling equipment; medium‑complexity film converting production lines.
Performance Parameters Minimum real‑time motion task cycle reaches 250 microseconds. Inter‑axis synchronization deviation stays below ±1 microsecond. Non‑volatile flash memory stores large‑volume historical fault logs for post‑failure analysis. Deterministic program execution timing maintains stable status under full‑load 8‑axis operating condition.
Material Composition Aluminum alloy shielding housing, FR‑4 high‑speed multilayer printed circuit boards, industrial real‑time processor chip, fiber‑optic transceiver modules, large‑capacity flash memory chips, plug‑in screw‑lock terminal blocks, SMD LED status indicator components.
Structural Characteristics Vertical DIN‑rail compatible housing form factor. Front panel arranges LED status indicator array, Ethernet service port and RS232 serial connector. SERCOS fiber‑optic connection ports locate on upper housing edge. Pluggable terminal blocks for digital I/O channels and DC24V power‑supply input are arranged on lower housing section. Metal identification nameplate permanently prints complete part number MAX‑4‑11‑03‑016‑08‑1‑1‑00. Internal circuit layout carries partitioned shielding design to suppress electromagnetic interference.
Working Principle User application program stored in internal flash memory runs on real‑time processor core. Logic processing section scans digital input signals, executes machine workflow sequence and generates digital output control actions. Motion processing section calculates position command values for each servo axis, transmits command data frames over SERCOS fiber‑optic bus to connected servo drives and integrated ISH motors. Status information and fault code feedback data return from drive units back to MAX‑4 controller. On‑board diagnostic modules continuously monitor hardware health state, communication link quality and I/O channel integrity. All configuration parameters and user program data keep retention status inside non‑volatile flash memory during power‑off events. Hardware watchdog circuit resets system automatically when abnormal program operation is detected.
Installation Requirements Install controller onto standard DIN‑rail inside properly grounded industrial control cabinet. Reserve sufficient surrounding clearance for natural convection heat dissipation. Comply strictly with minimum bending‑radius specifications for SERCOS fiber‑optic cables. Physically separate low‑signal communication wiring from high‑voltage motor‑power cables. Apply DC24V control‑power‑supply with strict polarity compliance. Connect protective‑earth terminal to cabinet protective‑ground busbar.
Usage Notes Forbid hot‑plugging SERCOS fiber‑optic connectors under powered operating condition. Complete full backup of user‑application program before firmware upgrade or hardware‑replacement work. Operate strictly within published ambient‑temperature operating‑range. Wear anti‑static wrist straps during internal circuit maintenance service. Prevent hardware exposure to conductive dust, heavy oil mist and corrosive industrial vapors.