Description
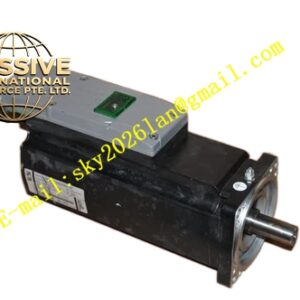
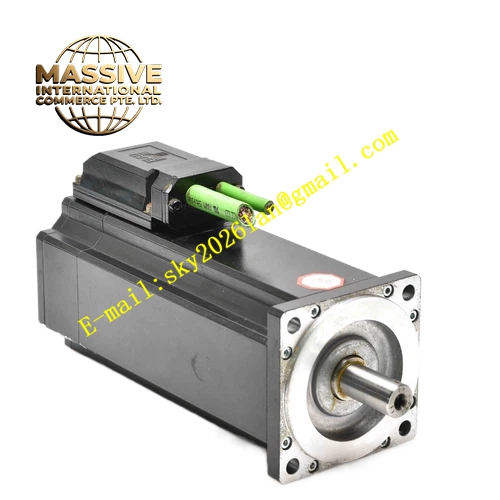
ELAU SM100-40-050-P1-45-S1-B0
Technical Specifications: Rated supply voltage 400 VAC, maximum speed 4000 rpm, continuous stall torque 5.0 Nm, peak torque 15.0 Nm, continuous current 7.0 A, peak current 14.0 A, encoder type Hiperface single‑turn absolute encoder, shaft diameter 22 mm, flange size 100 mm, insulation class F, protection rating IP65 for shaft and housing surfaces.
Functional Features: High‑density magnetic circuit design for low rotor inertia, high overload capacity for rapid acceleration and deceleration, absolute position feedback eliminates homing requirement after power‑on, rotatable quick‑connect connectors for flexible wiring, integrated thermal sensor for winding temperature monitoring, compatibility with SERCOS III bus servo drives.
Application Scenarios: Packaging production lines, printing presses, textile processing machines, electronic assembly equipment, material handling automation, multi‑axis robotic mechanisms, converting machinery.
Performance Parameters: Rotor inertia 12.5 kg·cm², thermal time constant 35 minutes, torque ripple below 2.5 %, positional feedback resolution 13‑bit single‑turn, operating ambient temperature range ‑20 °C to +40 °C.
Material Composition: Motor housing high‑strength cast aluminum alloy, stator silicon‑steel laminated core, high‑energy neodymium‑iron‑boron permanent magnet rotor, shaft high‑strength alloy steel, connector housing reinforced PA‑GF plastic.
Structural Characteristics: Fully enclosed fin‑cooled housing, B‑type shaft with keyway, separate power connector and encoder connector mounting on side face, flange‑mount installation structure, built‑in PT100 winding temperature sensor, no integrated holding brake for this variant.
Working Principle: Three‑phase AC sinusoidal current generates rotating magnetic field inside stator windings. Permanent magnet rotor follows magnetic field rotation. Hiperface encoder feeds real‑time shaft position and speed data back to servo drive. Drive executes closed‑loop position, speed and current control to achieve accurate motion output.
Installation Requirements: Mount via standard 100‑mm flange with metric fastening bolts; maintain alignment tolerance below 0.05 mm for coupling connection; retain minimum 50 mm clearance around motor housing for convection cooling; install inside control cabinet or protected machine enclosure; fix cable connectors securely to avoid vibration‑induced loosening.
Usage Notes: Do not apply radial or axial mechanical impact to motor shaft during installation; strictly match drive power rating and encoder communication protocol; avoid continuous operation above peak torque duration limit; prevent conductive dust, oil mist and liquid ingress past IP65 sealing surfaces; execute ESD protection during encoder‑side wiring; perform periodic tightening inspection of connector terminals under high‑vibration operating conditions.