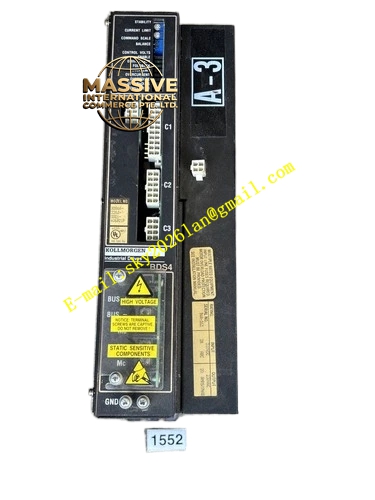
Description
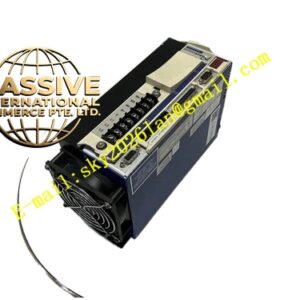
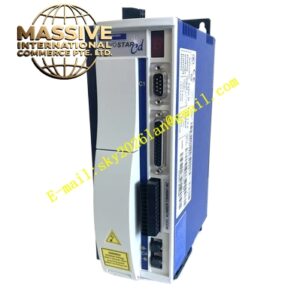
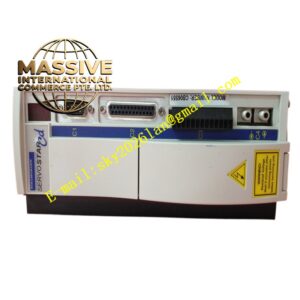
Kollmorgen BDS5T-203
Technical Specifications
- DC Bus Voltage Range: 225 VDC to 360 VDC
- Logic Power Requirements: ±15 to 20 VDC at 0.25 A; +8 to 12 VDC at 1.0 A
- Continuous Output Current: 3.0 Amps RMS
- Peak Output Current: 6.0 Amps RMS for 2.0 seconds
- Power Output Rating: 1.2 KVA continuous; 2.4 KVA peak at 160 VDC bus
- Heat Dissipation: 35 Watts
- Operating Modes: Position, velocity, and torque command modes
- Feedback: Resolver and incremental encoder compatible
Functional Features
- Built-in programming language with variables, math functions, and conditional commands
- Multi-tasking execution with 6 priority levels
- S-curve and trapezoidal motion profiling
- Electronic cam and gearbox functions
- Position capture and registration
- Software and hardware limit switch handling
- RS-232 serial interface with autobaud detection
- Real-time status monitoring and error logging
Application Scenarios
- Small precision positioning systems
- Laboratory automation equipment
- Light-duty packaging machinery
- Educational and research motion platforms
- Prototype development systems
Performance Parameters
- High-resolution position control with configurable units
- Smooth velocity transitions via S-curve acceleration
- Accurate torque delivery in current command mode
- Fast response to external trigger inputs
Structural Characteristics
- Compact industrial chassis with integrated heatsink
- Removable terminal blocks for field wiring
- Status LEDs for power, enable, and fault indication
- Expansion slot for compensation modules
Working Principle The drive executes stored motion programs or responds to serial commands. Internal processors calculate trajectory profiles and close position, velocity, and current loops in real time. Three-phase sinusoidal current is delivered to the brushless motor based on commutation angle derived from feedback devices. The torque mode specifically routes command signals directly to the current loop, bypassing velocity feedback for direct torque control applications.
Installation Requirements
- Panel mount in ventilated enclosure
- Ground all conductive surfaces per electrical code
- Use appropriate wire gauge for 3 Amp continuous current
- Install external regen resistor for high-inertia applications
Operating Precautions
- Verify all connections before initial power-up
- Configure current limits to match motor thermal ratings
- Allow adequate cooling time between peak current events
- Use shielded cables for all signal wiring