Description
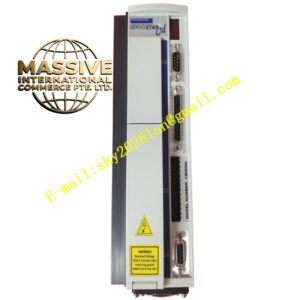
Kollmorgen CB06560
Technical Specifications
- Input Power: Three-phase AC 200–240V ±10%, 50/60Hz
- Continuous Output Current: 4.0A RMS
- Peak Current: 12.0A (30 seconds)
- Control Modes: Position, speed, torque, electronic cam, flying shear
- Feedback Interfaces: EnDat 2.2, Hiperface DSL, incremental encoders, resolvers
- Communication: EtherCAT, CANopen, Modbus TCP, Profinet (optional modules)
- Operating Temperature: -10℃ to +55℃ (derating required)
- Humidity: 5%–95% RH (non-condensing)
- Protection Class: IP20
- Dimensions: 82mm × 175mm × 140mm
- Weight: Approximately 1.8kg
- Safety Functions: STO (Safe Torque Off), SS1, SOS with SIL3 certification
Functional Features
- Sub-Micron Positioning: Advanced three-closed-loop control architecture achieving sub-micron accuracy.
- Multi-Protocol Support: EtherCAT, CANopen, Modbus TCP, and Profinet for seamless host integration.
- Comprehensive Safety: STO, SS1, and SOS functions certified to SIL3 level.
- Electronic Cam and Flying Shear: Built-in support for complex motion profiles.
- Wide Feedback Compatibility: Supports absolute encoders (EnDat 2.2, Hiperface DSL), incremental encoders, and resolvers.
Application Scenarios
- Industrial Automation: Multi-axis synchronous control for production lines.
- Robotics: Joint drive and trajectory planning.
- Printing and Packaging: Registration control and web tension management.
- Electronics Manufacturing: Precision pick-and-place and assembly equipment.
Performance Parameters
- Positioning Accuracy: Sub-micron level
- Speed Response: Fast dynamic response with S-curve acceleration/deceleration
- Current Loop: IGBT intelligent power modules with sine-wave current control
Material Composition
Industrial-grade IGBT power modules, high-quality DSP controller, and robust housing suitable for control cabinet installation.
Structural Features
Compact form factor with dimensions of 82mm × 175mm × 140mm, identical to CB06551 for parallel installation. Standardized connectors for power, feedback, and communication.
Working Principle
The drive receives motion commands via industrial Ethernet, preprocesses them with built-in motion controller for trajectory planning (S-curve acceleration/deceleration), then executes position, speed, and current closed-loop control. IGBT modules convert DC bus voltage into three-phase AC PWM waveforms to drive the servo motor with sine-wave current control for reduced harmonic losses.
Installation Requirements
- Install in a control cabinet with IP20 or higher protection.
- Ensure adequate ventilation around the drive.
- Connect feedback cables with proper shielding and grounding.
- Configure communication parameters according to the network topology.
Usage Notes
- Verify three-phase input voltage is within 200–240V ±10% range.
- Use Kollmorgen WorkBench software for parameter configuration and tuning.
- Monitor fault codes through the diagnostic interface.
- Ensure proper load inertia ratio setting (recommended ≤10) to minimize position following error.