Description
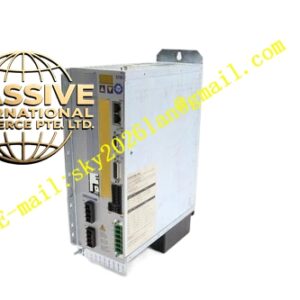
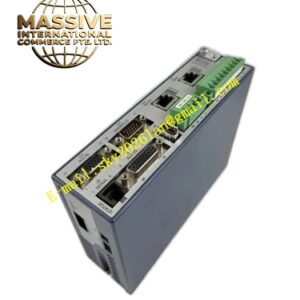
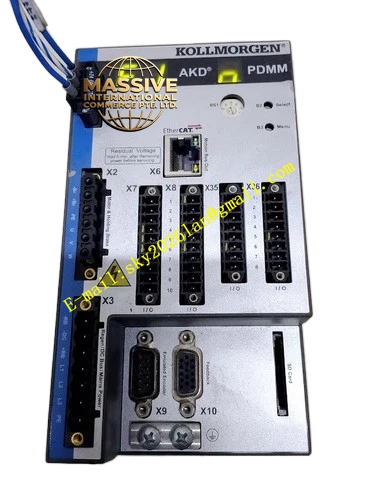
Kollmorgen controller AKD‑M00606‑MCEC‑E000
Technical Specifications: 120‑240 VAC single‑/three‑phase input; continuous output current 6 Arms; peak output current 18 Arms for 5 seconds; switching frequency 4‑8 kHz; EtherCAT fieldbus interface; STO safe‑torque‑off safety function; multi‑feedback support including SFD3, EnDat, BiSS, Hiperface DSL; built‑in digital and analog IO channels; SD‑card slot for program backup; 24 VDC auxiliary logic power supply; operating temperature 0 ℃‑55 ℃; storage temperature ‑20 ℃‑85 ℃; protection rating IP20; weight 2.0 kgKollmorgen.
Functional Features: Integrated motion controller and servo drive; multi‑axis coordinated motion control via EtherCAT; support electronic cam, electronic gear, position‑synchronization functions; STO SIL2 safety function; WorkBench software configuration and programming; motor plug‑and‑play identification; built‑in IO for sensor and actuator connection; program storage via SD card; comprehensive fault diagnosis function.
Application Scenarios: High‑speed packaging machinery, printing converting equipment, material‑processing automation, multi‑axis pick‑and‑place machines, special‑purpose automated production equipment.
Performance Parameters: Current‑loop update cycle 62.5 μs; velocity‑loop update cycle 125 μs; position‑loop update cycle 250 μs; support up to 64 total axes within one PDMM system; I²T thermal overload protection; hardware protection for over‑current, bus over‑voltage, bus under‑voltage, over‑temperature and feedback‑signal fault.
Material Composition: Die‑cast aluminum alloy housing; high‑performance IGBT power modules; gold‑plated high‑density industrial connectors; flame‑retardant high‑voltage PCB circuit board; metal heat‑sink fins; status LED indicator array; SD‑card socket.
Structural Features: Compact book‑style DIN‑rail‑mount housing; front‑panel LED status indicators; front‑side USB service port and SD‑card slot; lateral EtherCAT communication connectors; rear‑side power terminals, motor connector, feedback connector and IO terminals; convection‑plus‑fan‑assisted cooling.
Working Principle: Main‑circuit AC power is rectified to DC‑bus for power‑stage operation. 24 VDC auxiliary power supplies embedded motion‑controller CPU. The embedded CPU executes user‑written motion programs, generates motion set‑points for local servo axis and remote EtherCAT axes. Local power stage outputs three‑phase current to drive servo motor. Motor feedback signal feeds back to drive for closed‑loop computation. Hardware safety circuit implements STO safe‑torque‑off function. Comprehensive hardware monitoring detects all operating parameters and reports fault information.
Installation Requirements: Vertically install on DIN‑35 rail inside control cabinet; maintain 30 mm upper‑lower ventilation clearance and 15 mm left‑right clearance; EtherCAT communication cable uses shielded industrial Ethernet cable; separate power cables and signal cables with physical spacing; connect unit protective‑earth terminal to cabinet grounding bar reliably; STO safety‑circuit wiring follows safety‑standard requirement strictly.
Usage Notes: Do not perform live plug‑in of SD‑card and communication connectors during high‑power operation; wait for DC‑bus full discharge before maintenance work; do not exceed ambient temperature 55 ℃; firmware upgrade shall adopt matching official WorkBench software; spare‑part replacement must verify hardware revision and firmware compatibility.