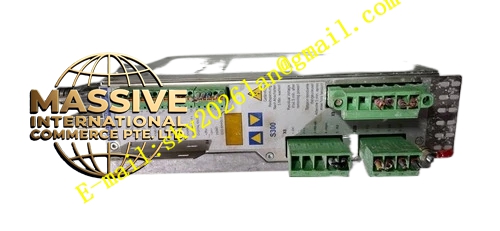
Description
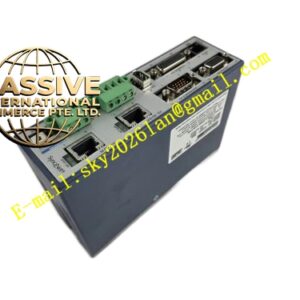
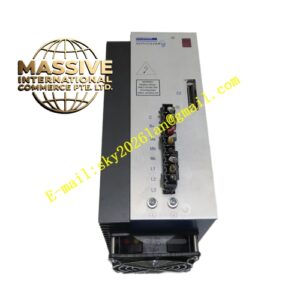
Kollmorgen S70101-FN3
- Technical Specifications:
- Series: ServoStar 700 (S700), S701 sub-series
- Type: Digital servo amplifier
- Rated Line Power: 1.1 kVA (S1 operation)
- Rated Output Current: 2.5 Arms at 1×110 V / 1×230 V; 2.0 Arms at 3×400 V; 1.5 Arms at 3×480 V
- Peak Output Current: 4.5 Arms
- Input Voltage: 1×110 V–230 V or 3×208 V–480 V, 50/60 Hz
- DC Bus Voltage: 290–675 VDC
- Auxiliary Power: 24 VDC
- Functional Features:
- High-speed digital current, velocity, and position control loops
- Onboard EtherCAT and CANopen fieldbus communication
- Dual-channel Safe Torque Off (STO) safety function (SIL2/PLd)
- Multi-feedback support: resolvers, SinCos encoders (BiSS, EnDat 2.1/2.2, HIPERFACE), incremental encoders, Hall sensors
- Integrated autotuning and cogging suppression algorithms
- IEC 61131-3 macro programming environment for custom motion logic
- Internal brake resistor and EMC filter
- Application Scenarios:
- Small-scale industrial automation and light-duty positioning systems
- Laboratory automation and medical device actuation
- Compact packaging machinery
- Precision indexing and pick-and-place applications
- Performance Parameters:
- Current loop update rate: 62.5 µs
- Velocity loop update rate: 62.5 µs
- Position loop update rate: 250 µs
- PWM switching frequency: 8 kHz
- Real-time response time under 1 ms
- Material Composition:
- Industrial-grade metal housing with integrated heat sink
- IGBT-based power switching modules
- Internal EMC filter components
- Structural Features:
- Compact panel-mount form factor designed for 300 mm switch cabinets
- Standard industrial connectors for power, motor, feedback, and fieldbus
- Embedded LED status display for diagnostics
- MMC storage card slot for parameter backup and firmware updates
- Working Principle:
- Operates as a closed-loop digital servo amplifier. The drive receives motion commands via fieldbus or analog/digital inputs, processes them through embedded PID control loops (current, velocity, position), and outputs precisely modulated PWM signals to the connected servo motor. Real-time feedback from the motor encoder or resolver is continuously compared against the command to minimize positioning error.
- Installation Requirements:
- Panel mounting in a ventilated control cabinet with adequate clearance for heat dissipation
- Use shielded cables for all motor power, feedback, and fieldbus connections
- Ensure proper grounding and equipotential bonding
- Provide stable 24 VDC auxiliary power supply
- Usage Notes:
- The “FN3” suffix indicates a specific feedback/network interface configuration — verify compatibility with the connected motor and controller before commissioning
- Verify motor nameplate parameters are correctly configured in the drive using the Windows-based GUI setup software
- This is a legacy product; consult Kollmorgen for AKD-series migration options