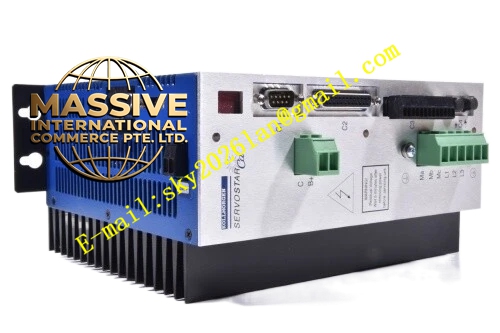
Description
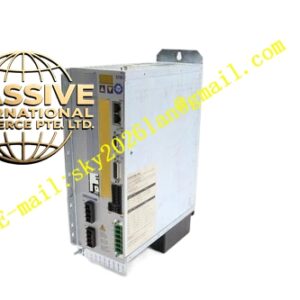
Kollmorgen S70301-FN2
- Technical Specifications:
- Series: ServoStar 700 (S700), S703 sub-series
- Type: Digital servo amplifier
- Rated Line Power: 2.2 kVA (S1 operation)
- Rated Output Current: 5 Arms at 1×110 V / 1×230 V; 4 Arms at 3×400 V; 3 Arms at 3×480 V
- Peak Output Current: 9 Arms
- Input Voltage: 1×110 V–230 V or 3×208 V–480 V, 50/60 Hz
- DC Bus Voltage: 290–675 VDC
- Auxiliary Power: 24 VDC
- Functional Features:
- Multi-mode servo control: torque, velocity, position, and programmable positioning
- Onboard EtherCAT and CANopen fieldbus communication
- Dual-channel STO safety function (SIL2/PLd)
- Multi-feedback support: resolvers (2–36 pole), SinCos encoders (BiSS, EnDat, HIPERFACE), incremental encoders, Hall sensors
- Integrated autotuning with four-channel oscilloscope and Bode plot display
- IEC 61131-3 macro programming (128 KB code memory, 62.5 µs cycle time)
- Internal brake resistor and EMC filter
- Application Scenarios:
- CNC machine tool axis drives
- Industrial robotics and material handling
- Automated assembly systems
- Semiconductor wafer handling equipment
- Performance Parameters:
- Current loop update rate: 62.5 µs
- Velocity loop update rate: 62.5 µs
- Position loop update rate: 250 µs
- PWM switching frequency: 8 kHz
- Peak current capability: up to 3× continuous rating for short bursts
- Material Composition:
- Rugged metal chassis with integrated heat sink
- IGBT-based power stage with protective circuitry
- Internal EMC filter components
- Structural Features:
- Panel-mount enclosure with standard industrial I/O connectors
- Embedded LED status display for diagnostics
- MMC storage card slot for parameter backup and firmware updates
- RS232 interface for full programming via PC
- Working Principle:
- Digital closed-loop servo control with PID regulation across current, velocity, and position loops. The drive processes motion commands, compares them with motor feedback in real time, and modulates PWM output to achieve precise torque, speed, or position control. The integrated macro programming environment allows customization of motion algorithms directly within the drive firmware.
- Installation Requirements:
- Mount in a well-ventilated control cabinet with adequate thermal management
- Use shielded cables for motor power, feedback, and fieldbus connections
- Ensure proper grounding and equipotential bonding
- Maintain minimum clearance for airflow around the drive
- Usage Notes:
- The “FN2” suffix indicates a specific feedback/network interface configuration — verify compatibility with the connected motor and controller
- Common fault codes include overcurrent, overvoltage, and encoder errors — refer to the instruction manual for diagnostics
- This is a legacy product; verify spare parts availability before procurement