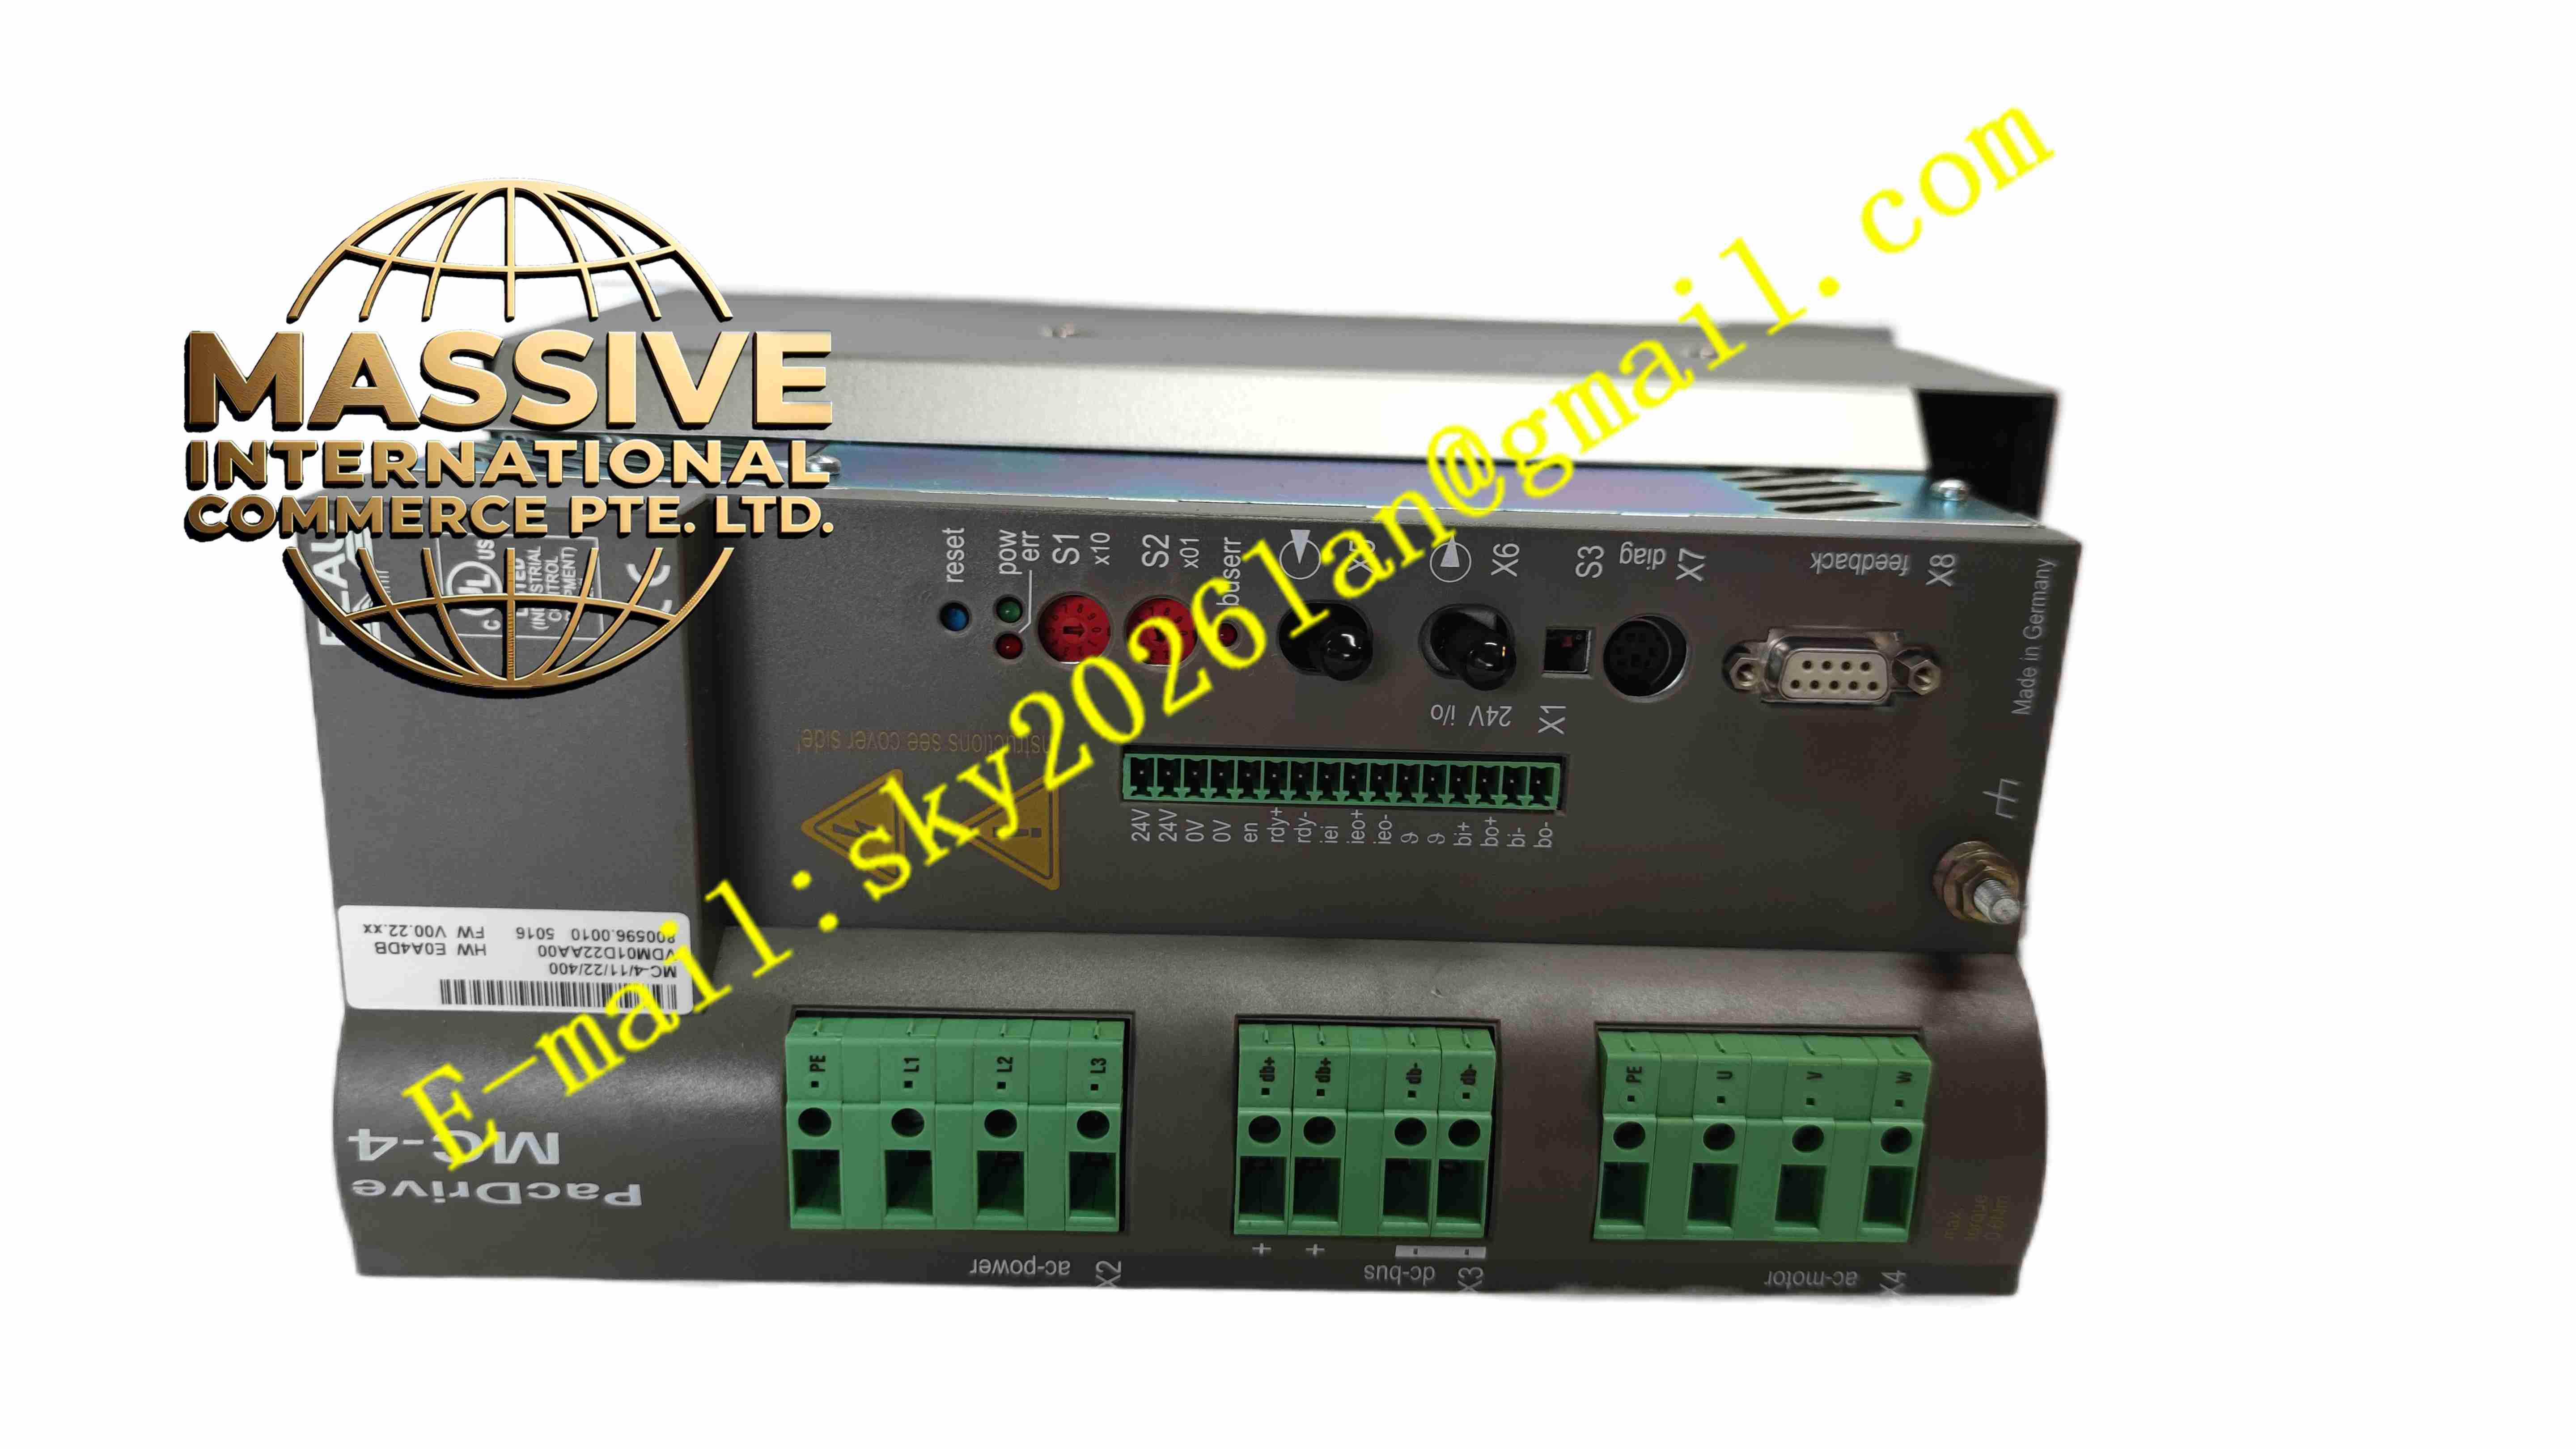
Description
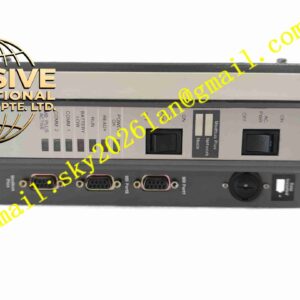
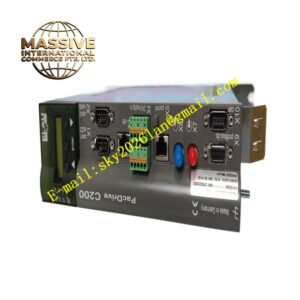
Schneider Electric MC-41105230V00.22.XX
Technical Specifications Single axis servo amplifier; 400VAC three-phase input; Real-time PacDrive servo bus; STO safety function; Support resolver and incremental encoder feedback; Firmware V00.22.XX; Rack installation; IP20 protection.
Functional Features Closed-loop position, speed and torque control; STO safe torque off; Complete hardware protection including over-current, over-temperature, short-circuit; Real-time bus communication with MAX-4 controller; Fault history storage; Parameter non-volatile saving; Firmware-specific motion function blocks for packaging machine cam motion.
Application Scenarios High-speed packaging machine servo axis; Carton handling and forming equipment; Pharmaceutical packaging line servo control; Converting machinery synchronized axis.
Performance Parameters Operating ambient temperature 0℃ to +55℃; Storage temperature -40℃ to +85℃; Relative humidity 5% to 90%, no condensation; Meets machinery safety standard requirements.
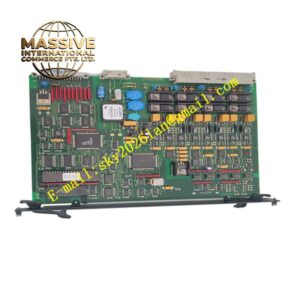
Material Composition Metal alloy housing with integrated heat sink; High-current IGBT power module; Multi-layer power PCB; DSP control chip; Current sampling sensors; Power filter capacitors; Screw power and signal terminals.
Structural Characteristics Vertical rack plug-in module; High-current power terminals at bottom, encoder and bus signal terminals at top; Internal isolation layout between high-power circuit and low-voltage signal circuit; Rear large-area heat sink for cabinet forced air cooling.
Working Principle Three-phase AC input converts to DC bus voltage. DSP chip runs V00.22.XX firmware, receives motion command from MAX-4 controller, generates PWM pulse to drive IGBT module and outputs variable frequency AC to servo motor. Motor position feedback forms closed-loop adjustment. STO safety circuit cuts off torque output once safety interlock triggers.
Installation Requirements Install module on PacDrive M rack and lock buckle. Ensure cabinet cooling air flows through heat sink. Use shielded motor and encoder cables, separate power and signal routing. Complete protective earthing. After power-on, confirm firmware version and execute motor parameter self-identification.
Usage Notes Firmware version must match machine program version. Backup drive parameters before replacement. Wait for DC bus capacitor discharge before wiring disassembly. Keep heat sink free of dust accumulation.