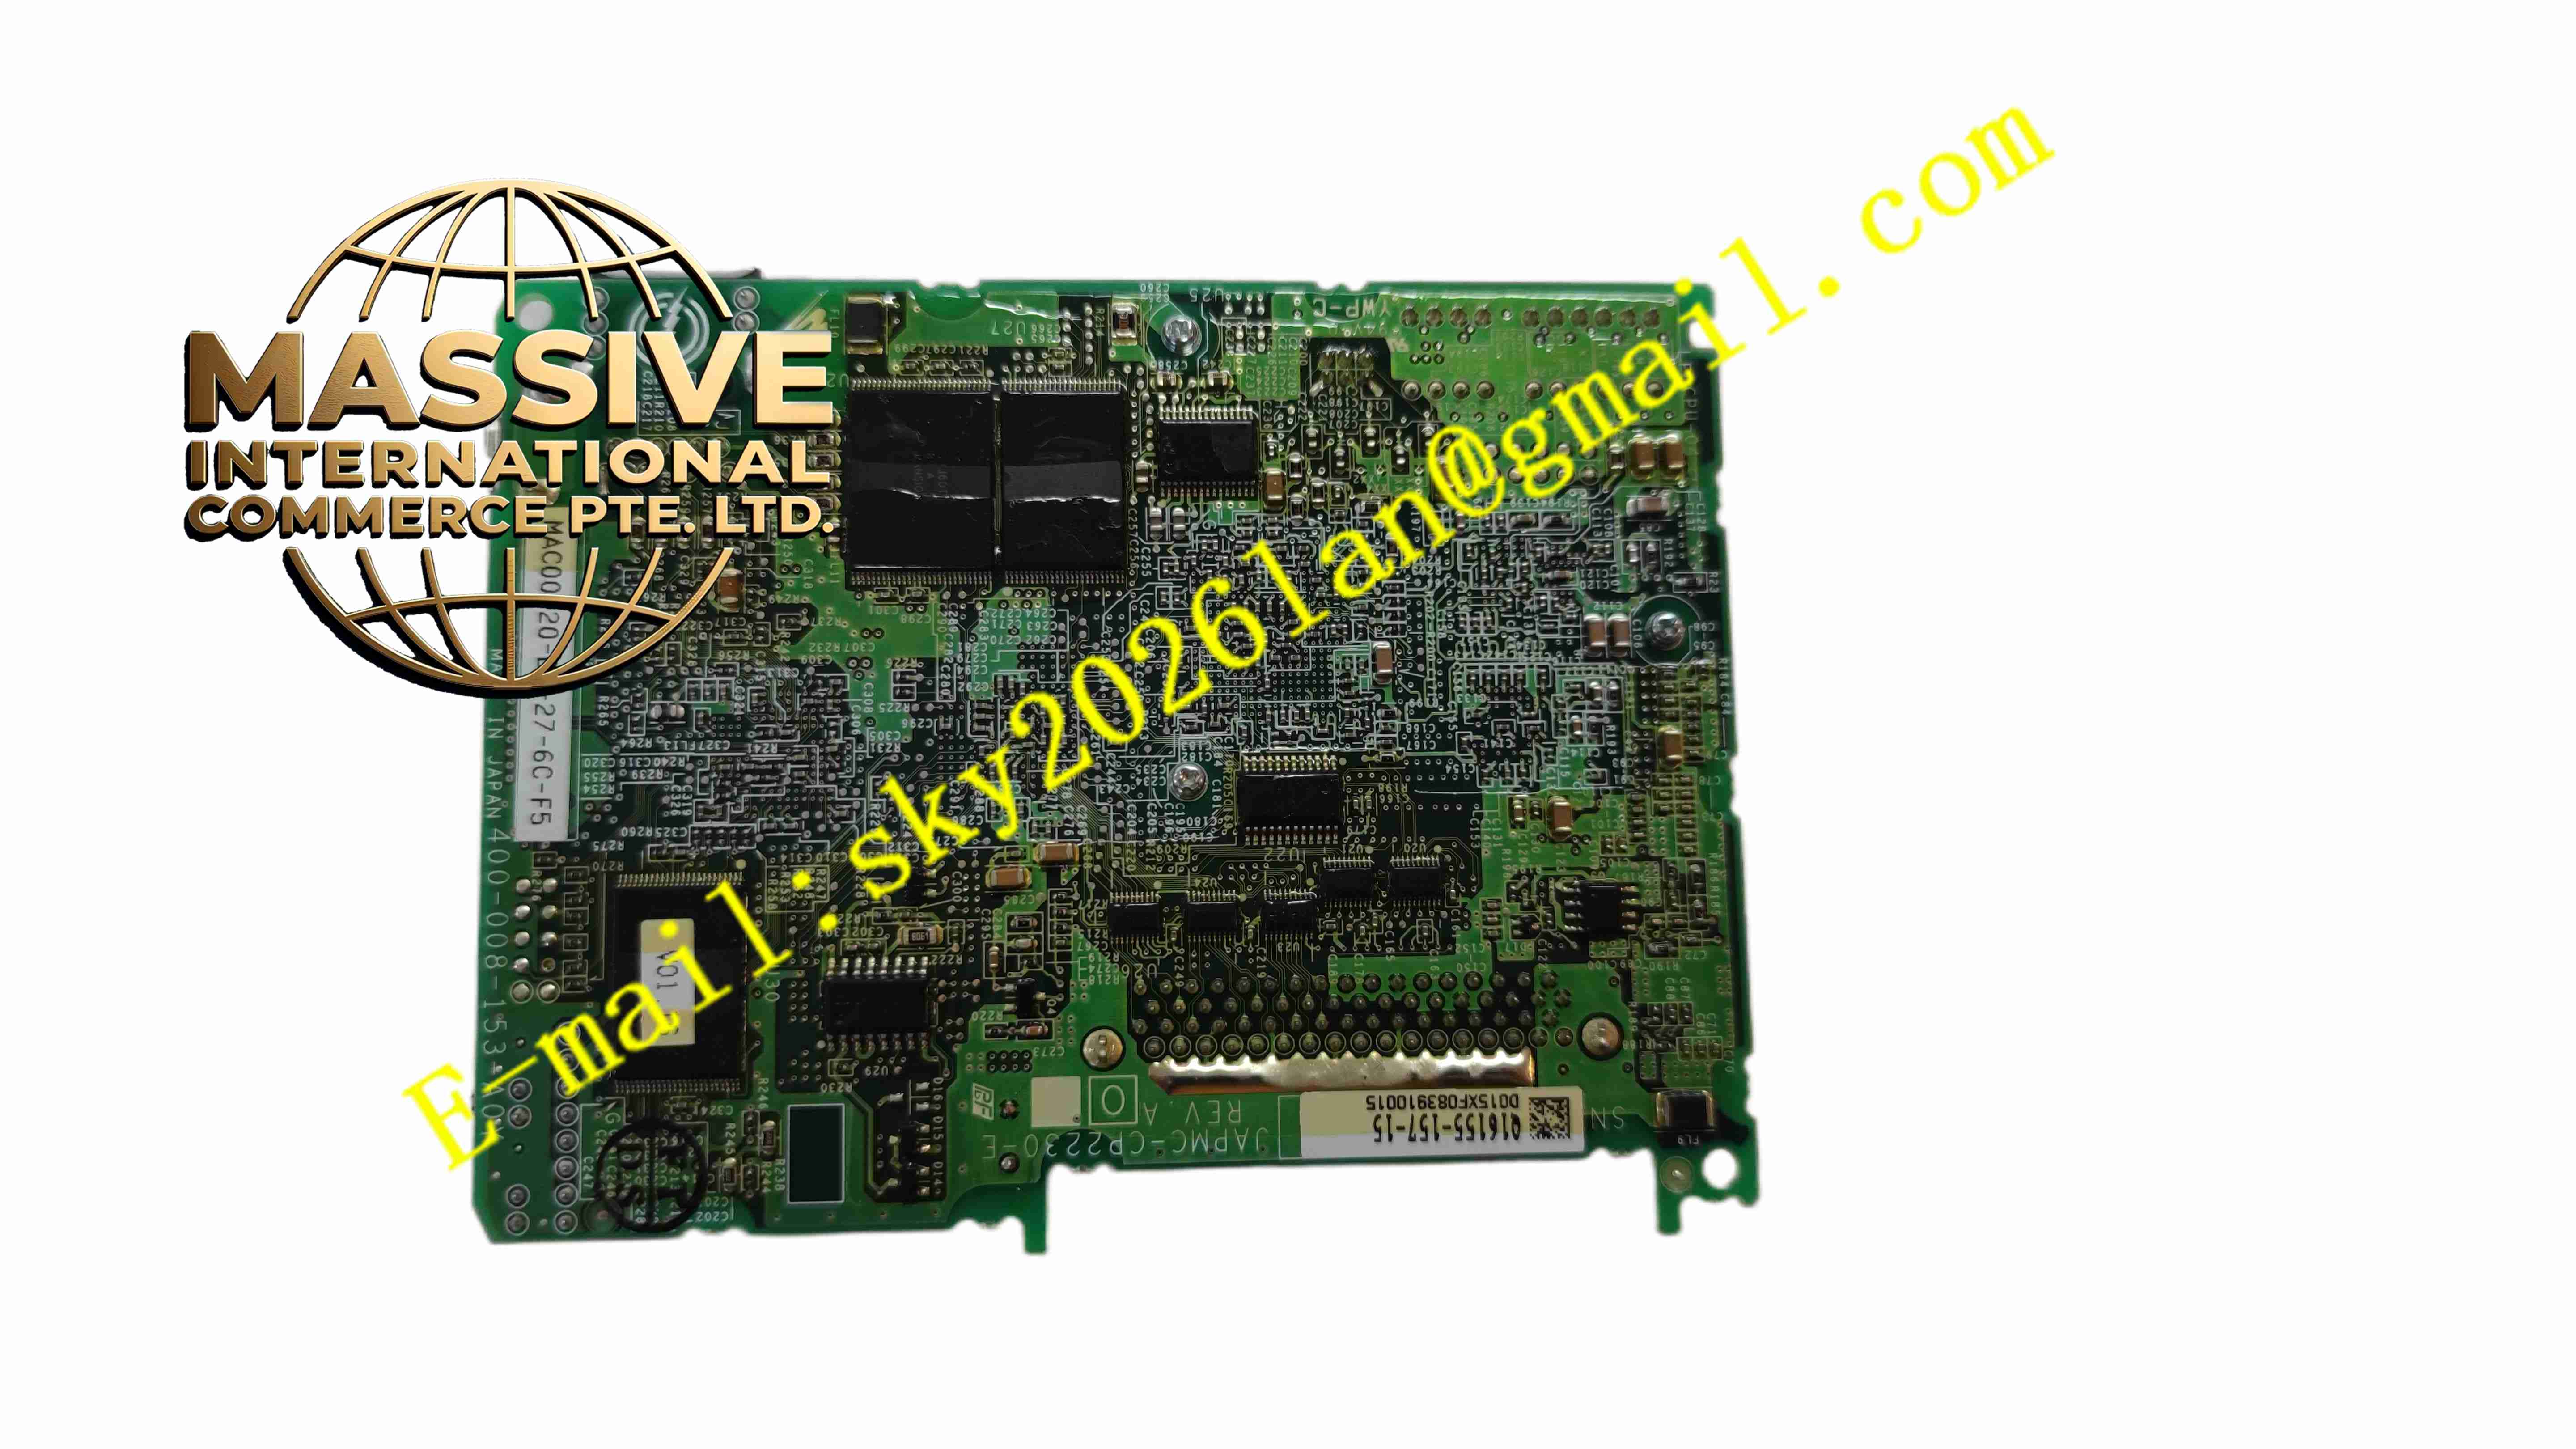
Description
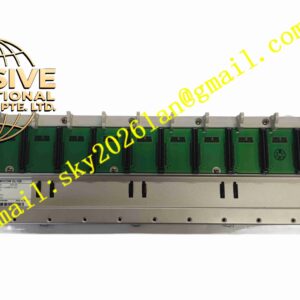
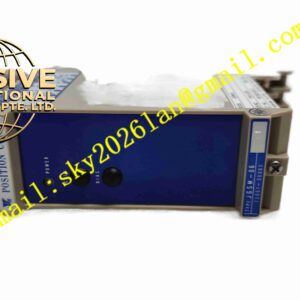
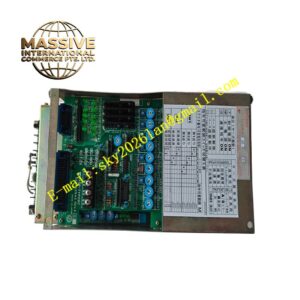
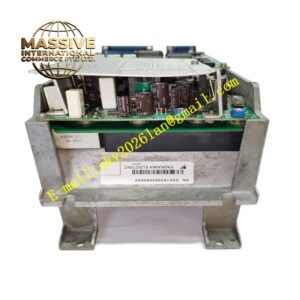
Yaskawa JAPMC-CP2230-E
Technical Specifications MP2200 rack CPU module; Multi-axis motion control capacity; Mechatrolink II servo bus interface; Ethernet port for host communication; Flash memory for user program; Real-time clock; Backplane bus communication with I/O modules; DIN rack installation.
Functional Features Multi-axis synchronous motion control; Support linear interpolation, circular interpolation, electronic cam and electronic gear function; Mechatrolink II high-speed servo bus for servo drive connection; Ethernet communication with HMI and host computer; User program storage in non-volatile flash memory; Hardware watchdog function; Built-in diagnostic for bus and module fault; Support multiple I/O expansion modules.
Application Scenarios Packaging machinery multi-axis control; Printing equipment motion control; Automated assembly production line; Material handling robot; Metal processing machine tool auxiliary axis control.
Performance Parameters Operating temperature 0℃ to +55℃; Storage temperature -40℃ to +85℃; Relative humidity 10% to 90% no condensation; Vibration resistance meets IEC industrial automation standard.
Material Composition Flame-retardant plastic module housing; Multi-layer PCB; Industrial motion control DSP chip; Flash memory chip; Mechatrolink bus isolation circuit; Gold-plated backplane connector; LED status indicators.
Structural Characteristics Compact rack-mounted single slot module; Back gold finger connects to MP2200 backplane; Front panel with status LED and communication ports; Internal circuit partitions for motion bus and logic control circuit.
Working Principle Module obtains power from MP2200 backplane. User motion program stored in flash memory runs on CPU chip. The module sends high-speed motion command through Mechatrolink II bus to Yaskawa servo drives, reads encoder feedback and implements closed-loop motion control. It exchanges logic data with I/O modules via backplane and uploads running information to HMI over Ethernet.
Installation Requirements Power off MP2200 rack before installation. Insert module into empty rack slot and lock the module buckle. Connect Mechatrolink bus cable and Ethernet cable. Download user motion project by MotionWorks software, configure servo axis parameters and test axis movement. Rack reliable protective earthing is required.
Usage Notes Do not hot-swap the CPU module. Backup user program before module replacement. Use shielded bus cable for Mechatrolink II wiring. Avoid strong electromagnetic interference nearby. Check ventilation of control cabinet to prevent overheating.