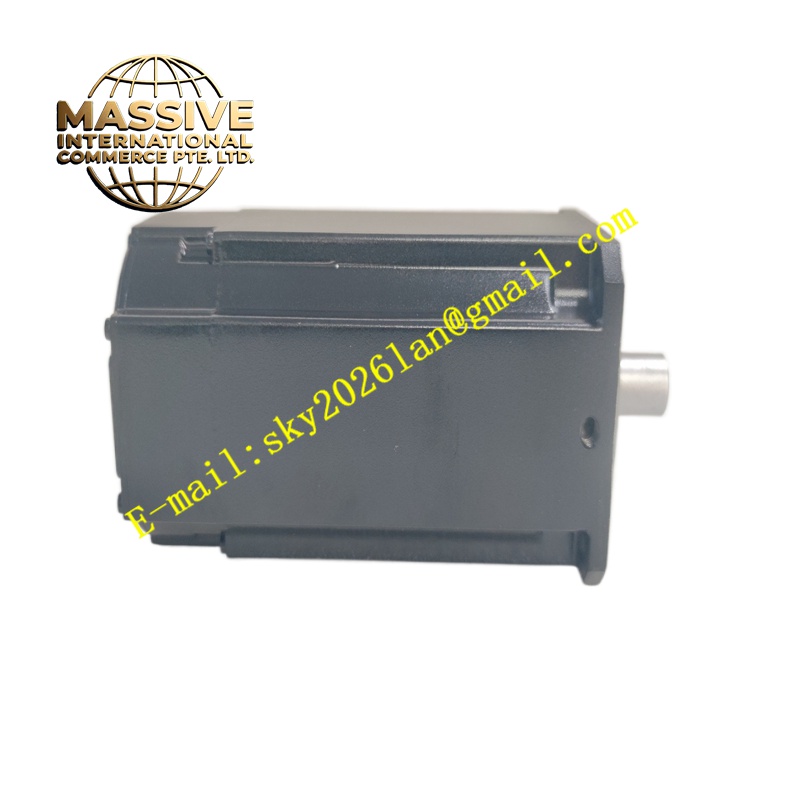
Description
Kollmorgen AKM33E-ANCNR-00
Technical Specifications Permanent magnet brushless synchronous design; rated torque, peak torque and rated speed defined by model code; built-in high-resolution incremental encoder; 230V AC power input; IP65 protection rating for motor housing; operating ambient temperature -20°C to +40°C; sealed bearing assembly; optional brake configuration defined by model suffix.
Functional Features Generates precise torque output under servo drive control for position, speed and torque control modes. Built-in encoder feeds rotor position and speed data back to the servo drive to form closed-loop control. Delivers high peak torque for fast acceleration and deceleration of machine axes. Supports zero-speed holding function when equipped with holding brake. Low torque ripple ensures smooth motion at low speed.
Application Scenarios Precision CNC machinery, electronic assembly automation, robotic joint axes, 3C product testing platforms, packaging and labeling machines, medical automation equipment.
Performance Parameters High torque density; fast dynamic response for rapid acceleration and deceleration; low cogging torque and smooth low-speed operation; high encoder feedback precision for micron-level positioning.
Material Composition Motor stator core uses silicon steel sheet; rotor adopts high-performance neodymium iron boron permanent magnet; motor housing uses black anodized aluminum alloy; winding insulation adopts high-temperature resistant enameled wire; front and rear bearings are high-precision sealed ball bearings; encoder PCB uses FR-4 substrate.
Structural Characteristics Compact cylindrical housing with flange mounting form. Shaft end adopts standard keyway or smooth shaft according to model definition. Rear housing integrates encoder assembly and connector ports for power and feedback cables. Internal stator and rotor assembly sealed inside the aluminum housing. Terminal connectors have locking structure for vibration resistance.
Working Principle The servo drive outputs three-phase alternating current to the motor stator winding to generate a rotating magnetic field. The magnetic field interacts with the permanent magnet rotor to produce electromagnetic torque and drive shaft rotation. The built-in encoder continuously detects rotor angle and sends position signals back to the drive. The drive adjusts current vector in real time to maintain target speed or position.
Installation Requirements Mount the motor flange on the machine mechanical bracket and fasten mounting screws with specified torque. Couple the motor shaft to the mechanical load with a suitable coupling. Connect power cable and encoder feedback cable to the rear connectors. Configure motor parameters including pole count, encoder type and inertia in servo drive software. Perform auto-tuning of servo loop after mechanical assembly.
Precautions for Use Do not apply radial or axial load exceeding the bearing rating to the motor shaft. Protect the motor from continuous exposure to oil mist and corrosive gas. Execute thermal protection monitoring during operation. Run motor direction test without load before connecting mechanical loads.