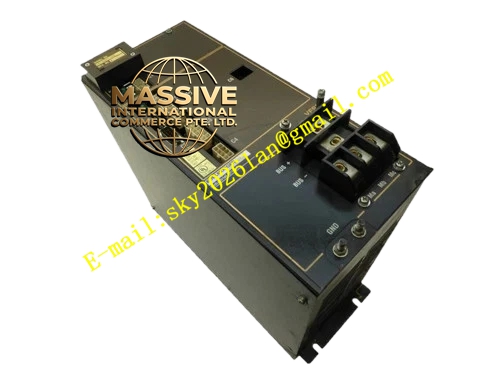
Description
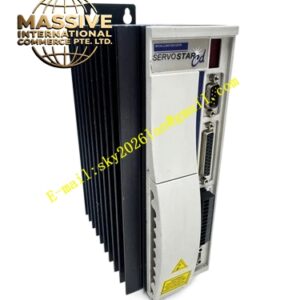
Kollmorgen BDS4A-203J-0028
Technical Specifications
- Input Voltage: 230 VAC, three-phase
- DC Bus Voltage: 310 VDC
- Continuous Output Current: 3.0 Amps
- Control Mode: Analog velocity/torque mode
- Motor Compatibility: Brushless DC (synchronous permanent magnet) servo motors
- Feedback: Resolver and incremental encoder interfaces
Functional Features
- Analog velocity loop control with adjustable gain compensation
- Current command mode for direct torque control applications
- Resolver feedback processing for absolute position information
- Encoder input for incremental position feedback
- Hardware overtravel and fault protection circuits
- Status output for drive ready and fault conditions
- Regenerative braking capability with external resistor connection
Application Scenarios
- Legacy industrial machinery requiring BDS4 series replacement drives
- Small to medium precision positioning systems
- Machine tool axis control
- Material handling equipment
- Automated assembly machinery
- Retrofit applications maintaining BDS4 architecture
Performance Parameters
- 3 Amp continuous current supports small to medium frame servo motors
- 310 VDC bus voltage provides adequate margin for 230 VAC input operation
- Analog control loops deliver smooth velocity regulation
- Compatible with Kollmorgen GOLDLine and Silverline brushless motor families
Material Composition and Structure
- Steel and aluminum industrial chassis with integrated heatsink
- Modular analog and digital control circuit boards
- Isolated power and logic sections for electrical noise immunity
- Heavy-duty terminal blocks for 230 VAC and motor power connections
- Status LED indicators for power, enable, and fault states
Working Principle The drive rectifies three-phase 230 VAC input to establish a 310 VDC internal bus. The analog control circuitry processes velocity command inputs and compares them against actual motor velocity derived from feedback devices. The current loop generates PWM gate signals for the three-phase output stage, delivering controlled sinusoidal current to the brushless motor. Electronic commutation is determined from resolver or encoder feedback, ensuring proper rotor alignment for maximum torque production.
Installation Requirements
- Mount in NEMA-rated electrical enclosure with adequate ventilation
- Connect three-phase 230 VAC supply with proper overcurrent protection
- Use shielded cables for motor power and feedback connections
- Install external regeneration resistor if application demands high deceleration rates
- Ensure all ground connections comply with electrical code standards
Operating Precautions
- Verify input voltage and phasing match drive specifications before energizing
- Confirm motor feedback device type matches drive configuration
- Configure current limits to protect motor from thermal overload
- Monitor heatsink temperature during extended operation