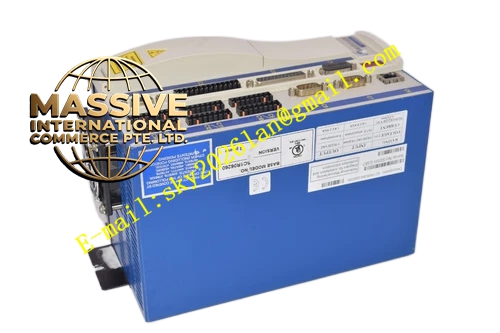
Description
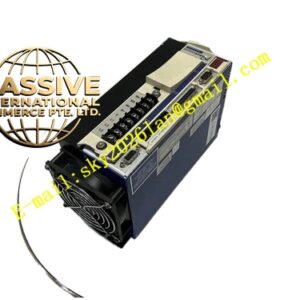
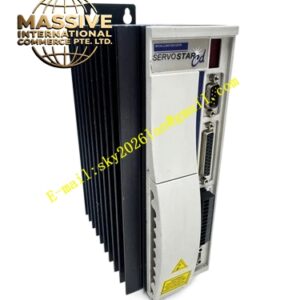
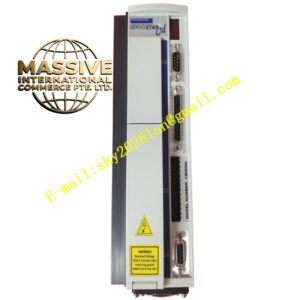
Kollmorgen SC1R06260
Technical Specifications
| Parameter Category | Specific Specification |
|---|---|
| Manufacturer | Kollmorgen (Danaher Motion) |
| Product Family | SERVOSTAR SC Series |
| Power Supply | 1/3-Phase, 115/230 VAC nominal |
| Input Current | 10/7.8 Amps per phase (115/230 VAC) |
| Input Power | 1.4/2.2 kVA (115/230 VAC) |
| Output Voltage | 115/230 VAC |
| Output Current | 6.0 Amps RMS continuous per phase |
| Peak Output Current | 12.0 Amps RMS (2 seconds) |
| Output Power | 1.0/1.8 kVA (115/230 VAC) |
| PWM Frequency | 8 kHz |
| Control Modes | Position, velocity, torque (position control standard) |
| Command Interface | ±10V analog, step/direction, indexer, CANopen |
| Feedback | Resolver (standard), incremental encoder (optional) |
| Position Control | Built-in indexer with 64 motion profiles |
| I/O | 4 digital inputs, 2 digital outputs, 1 analog input |
| Protection | Overcurrent, overvoltage, undervoltage, overtemperature, position error |
| Operating Temperature | 0°C to +45°C |
| Storage Temperature | -25°C to +70°C |
| Protection Class | IP20 |
Key Features
- Built-In Position Control: Integrated indexer eliminates need for external motion controller in many applications
- 64 Motion Profiles: Stores up to 64 pre-programmed motion profiles in non-volatile memory
- Multiple Command Sources: Accepts analog, step/direction, or CANopen commands for flexible integration
- Resolver Feedback Standard: Robust resolver interface suitable for harsh industrial environments
- Compact Design: Space-saving enclosure ideal for distributed automation architectures
- Auto-Tuning: Automatic loop gain adjustment simplifies commissioning
- CANopen Interface: Standard CANopen communication for integration into fieldbus networks
Application Scenarios
- Stand-alone positioning: Drives linear stages, rotary tables, and pick-and-place mechanisms without external controller
- Packaging machinery: Controls indexing conveyors, labeling stations, and carton handling with pre-programmed profiles
- Material handling: Powers belt drives, chain conveyors, and automated guided vehicles with precise positioning
- Textile machinery: Controls yarn tensioning, pattern selection, and fabric handling with synchronized motion
- Food processing: Drives filling, capping, and sealing equipment with hygienic design compatibility
- Woodworking: Controls saw positioning, drill heads, and edge banding equipment
- Printing machinery: Drives registration control, ink key positioning, and paper feed mechanisms
Performance Parameters The SC series achieves a position loop update rate of 1 millisecond with 32-bit position resolution. The velocity loop bandwidth is 400 Hz, suitable for most positioning applications. The current loop bandwidth is 1.5 kHz. Positioning accuracy is within ±1 encoder count with proper tuning. The indexer supports absolute, relative, and continuous motion profiles with programmable acceleration, deceleration, and maximum velocity. Home search routines include multiple homing methods (limit switch, home sensor, encoder index). The drive supports electronic gearing and camming functions.
Material Composition The drive enclosure is constructed from aluminum with a durable painted finish. Power semiconductors are compact IPM packages. The control board uses a 4-layer PCB with mixed surface-mount and through-hole components. DC bus capacitors are compact electrolytic types. The heat sink is an extruded aluminum profile. Front panel is plastic with LED indicators. Internal position control firmware is stored in flash memory with battery-backed RAM for profile storage.
Structural Characteristics The drive features a compact rectangular enclosure designed for DIN rail or panel mounting. Power terminals are screw-type spring clamps. Control connectors are pluggable terminal blocks. The front panel includes status LEDs (power, run, fault, position ready) and a communication port connector. Internal layout places the power stage at the bottom with the control board above. Cooling is by natural convection with optional fan. The base includes DIN rail clip and panel mounting slots.
Working Principle AC input is rectified to DC bus voltage. The IPM inverter generates variable-frequency output. The built-in position controller executes stored motion profiles or responds to external commands. Position feedback from the resolver is converted to digital counts. The position loop compares commanded position against actual position, generating velocity commands. The velocity loop processes these against actual velocity. The current loop regulates motor current. The indexer can execute complex motion sequences autonomously, triggering outputs and reading inputs at programmed positions.