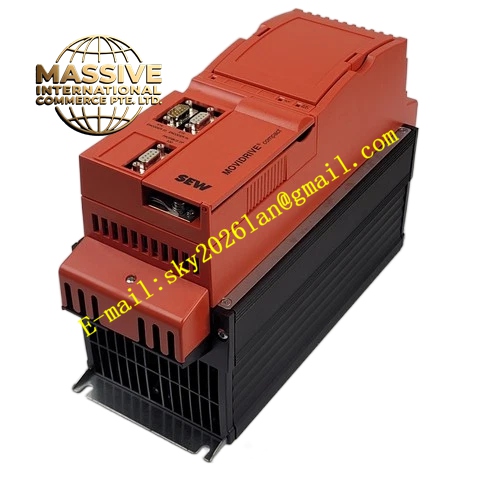
Description
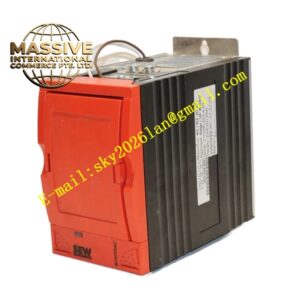
SEW MDS60A0055-5A3-4-00
Technical Specifications:
- Brand: SEW-EURODRIVE
- Series: MOVIDRIVE MD 60A
- Type: MDS (SERVO operating mode)
- Recommended Motor Power: 5.5 kW
- Supply Voltage: 3-phase AC 380–500V, 50/60 Hz
- Operating Mode: SERVO (CFC with resolver)
- Quadrants: 4Q (with brake chopper)
- Input Filter: Integrated
- Protection Class: IP20
- PWM Frequency: Fixed at 8 kHz in SERVO mode
- Speed Range: -5000 to +5000 rpm
- Speed Resolution: 0.2 rpm
Functional Features:
- SERVO Operating Mode: Exclusively supports CFC (Current Flux Control) with resolver feedback for synchronous motors, delivering high-precision speed and position control
- Four-Quadrant Operation: Built-in brake chopper enables regenerative braking and rapid deceleration
- Integrated Input Filter: Reduces electromagnetic interference and ensures EMC compliance
- Modular Option Card Slots: Two option card slots (OPTION1 and OPTION2) for fieldbus communication modules, digital I/O expansion, and encoder interfaces
- IPOSplus Motion Controller: Integrated programmable positioning and logic control system for autonomous motion sequences
- Comprehensive Protection Suite: Overcurrent, overvoltage, undervoltage, overheating, ground fault, and motor stall protection
- System Bus (SBus): CAN-based master-slave communication for multi-drive synchronization
Application Scenarios:
- Synchronous servo motor drives requiring precise position and speed control
- Machine tool feed axes
- Automated assembly and packaging machinery
- Precision conveyor systems
- Winding and unwinding applications
- Robotic positioning systems
Performance Parameters:
- Continuous Output Current: 12.5 A (at 400V, SERVO mode)
- Output Frequency Range: 0–500 Hz
- Overload Capacity: 150% rated current for 60 seconds
- Speed Control Accuracy: High precision with resolver feedback
- PWM Switching Frequency: Fixed at 8 kHz
Material Composition:
- Industrial-grade IGBT power modules
- Conformal-coated control circuit boards
- Aluminum heat sink with forced air cooling
- Integrated EMC/RFI filter components
- Steel housing with powder-coated finish
Structural Features:
- Compact cabinet-mount housing with modular design
- Power supply input terminals (L1, L2, L3)
- Motor output terminals (U, V, W)
- Braking resistor terminals (+R, -R)
- Two option card PCB slots (OPTION1 and OPTION2)
- Control card slot (CONTROL)
- Signal terminal connectors (X10–X13)
- Power shield clamp for cable grounding
- LED status and diagnostic indicators
- DBG keypad interface
Working Principle:
The inverter converts three-phase AC input power through a rectifier stage into DC bus voltage, which is smoothed by capacitors. The IGBT inverter stage synthesizes variable-frequency, variable-voltage PWM output to control the connected synchronous motor. In SERVO mode, the resolver attached to the motor provides real-time rotor position feedback, enabling precise field-oriented current flux control (CFC). The control algorithm decouples flux and torque components for independent regulation, achieving high dynamic response and positioning accuracy.
Installation Requirements:
- Mount vertically inside a control cabinet with at least 100 mm clearance above and below for cooling airflow
- No side clearance required; units can be lined up in rows
- Use shielded motor cables with 360° shield grounding via the power shield clamp
- Connect the resolver cable to the appropriate option card interface
- Connect braking resistor to dedicated braking terminals for 4Q operation
- Ensure ambient temperature remains within -10°C to +40°C operating range
Usage Precautions:
- Perform motor initialization and auto-tuning after connecting a new motor
- Use MOVITOOLS software or DBG11A keypad for parameter configuration and commissioning
- Never connect or disconnect power or motor cables while the inverter is energized
- Monitor fault codes via the LED display or MOVITOOLS software
- Clean heat sink fins regularly to prevent overheating
- Wait at least 5 minutes after disconnecting main power before performing maintenance to allow capacitor discharge
- Verify supply voltage stability within ±10% tolerance before operation
- Ensure the resolver is properly connected and calibrated before enabling SERVO mode